Sep 2026
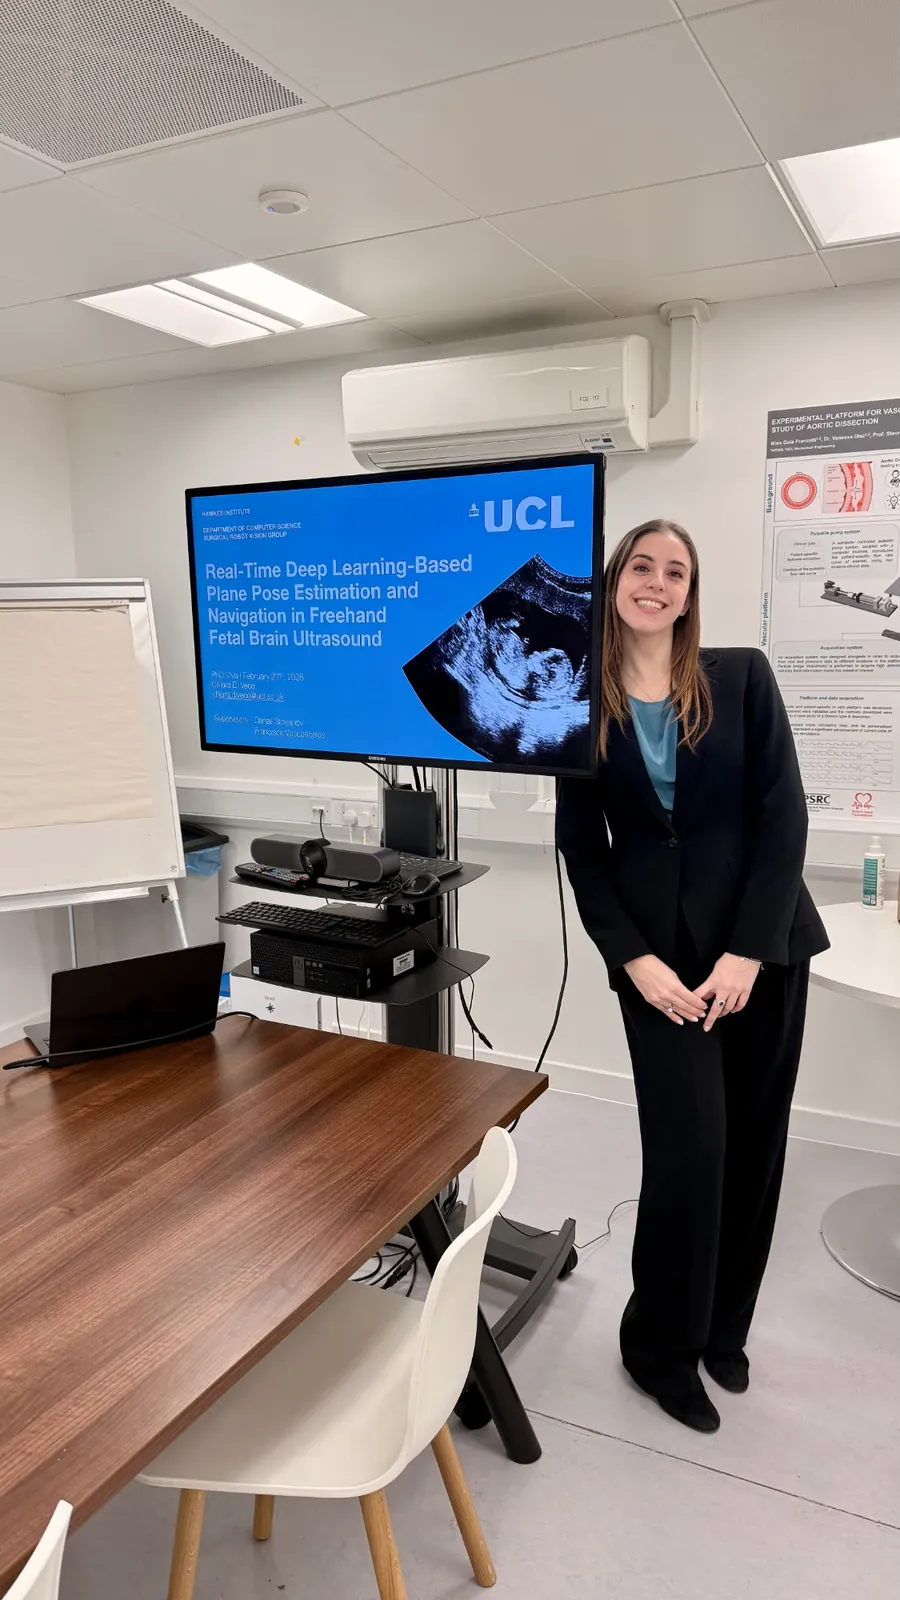
My PhD in Computer Science from UCL has been officially awarded. The thesis is on real-time deep learning-based plane pose estimation and navigation in freehand fetal brain ultrasound.
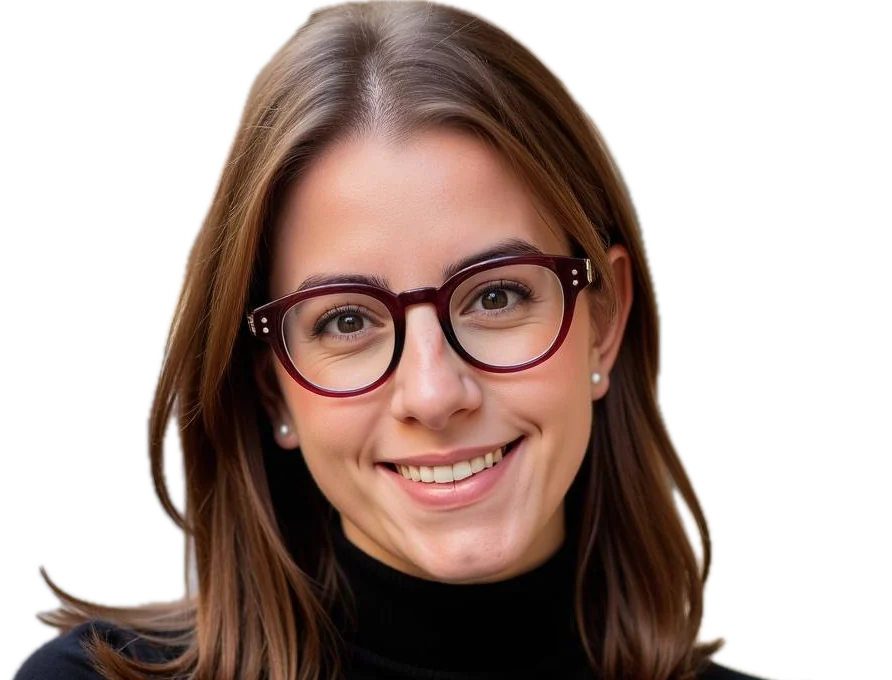
I build real-time perception for things that move: first an ultrasound probe over a fetal brain, now soft robots. I lead AI at morph, a soft robotics startup still in stealth.
My PhD at UCL taught deep learning models to guide sonographers to the right views in fetal brain ultrasound, without any tracking hardware, in real time on NVIDIA's Clara AGX. Before that I built surgical simulators with haptics and VR in Milan and Chicago. I also trained in ballet for fifteen years.
Citations and h-index from Google Scholar, updated October 2026.
Sep 2026
My PhD in Computer Science from UCL has been officially awarded. The thesis is on real-time deep learning-based plane pose estimation and navigation in freehand fetal brain ultrasound.
Jul 2026
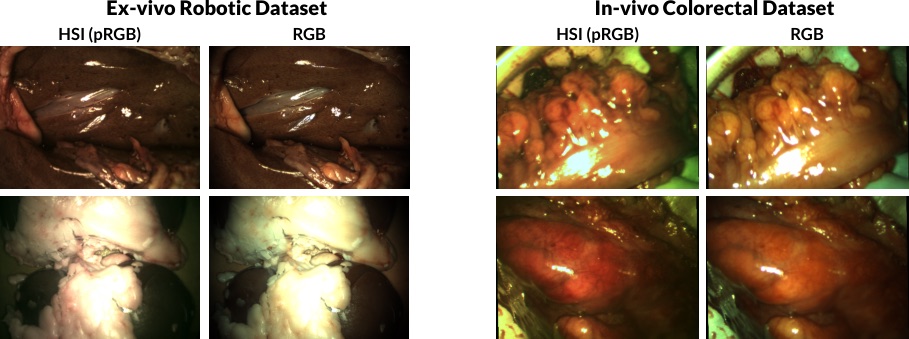
HyKey, our hyperspectral keypoint detection and matching method for minimally invasive surgery, was presented at IPCAI 2026 in Nagoya. The dataset and code are public. Dataset and code
Apr 2026
Our multicentre benchmark dataset for landmark-based fetal ultrasound biometry is out in Scientific Reports, with open data and code. Read the paper
Feb 2026
I defended my PhD at UCL and passed with minor corrections. Thank you to my supervisors Dan Stoyanov and Francisco Vasconcelos, and to my examiners Ester Bonmati and George Mylonas.
May 2025
"Mismatched", our study of where image matching methods and benchmarks break down, is published in the ECCV 2024 Workshops proceedings. Read the paper
Apr 2025
Our robotic arm platform for multi-view image acquisition and 3D reconstruction in minimally invasive surgery is published in IEEE Robotics and Automation Letters. Read the paper
Mar 2025
I presented FETUS, our freehand ultrasound training system, at Innovation in Women's Health Tech 2025 in London. Our Women's Health Tech Grant project was also named one of the top 3.
My PhD taught machines to find their way through fetal ultrasound. Now I build AI for soft robots.
The thread across all three: real-time perception, in imaging, in surgery and in simulation.
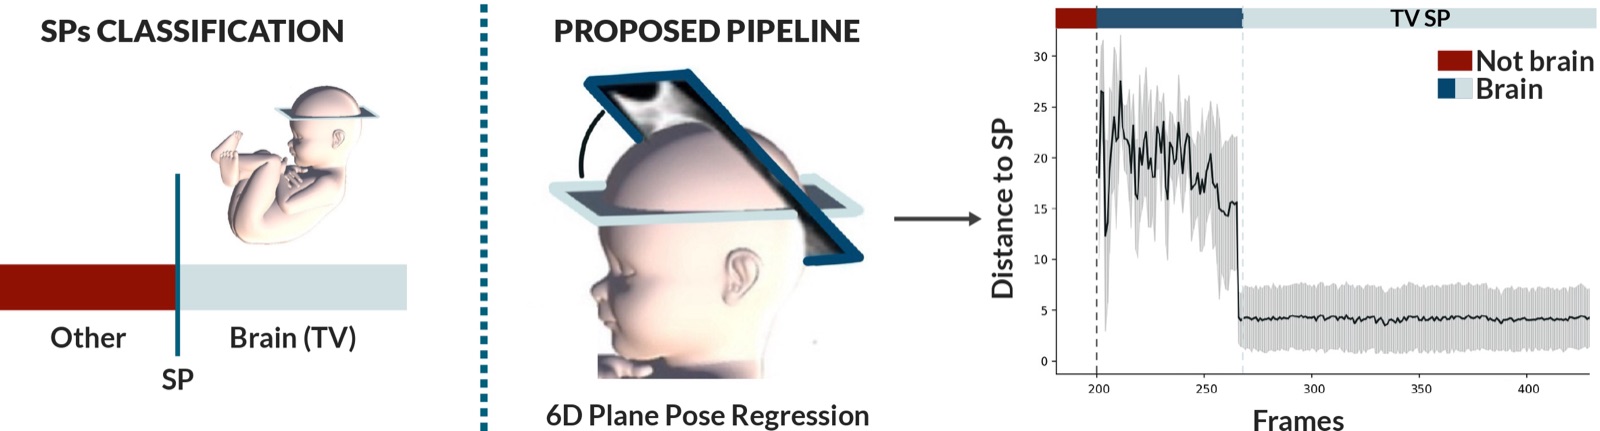
Sensorless 6D plane pose regression that tells a sonographer how far they are from a diagnostic standard plane, using only the 2D video stream, deployed in real time (3 ms) on NVIDIA Clara AGX. Plus a multicentre benchmark for fetal biometry.
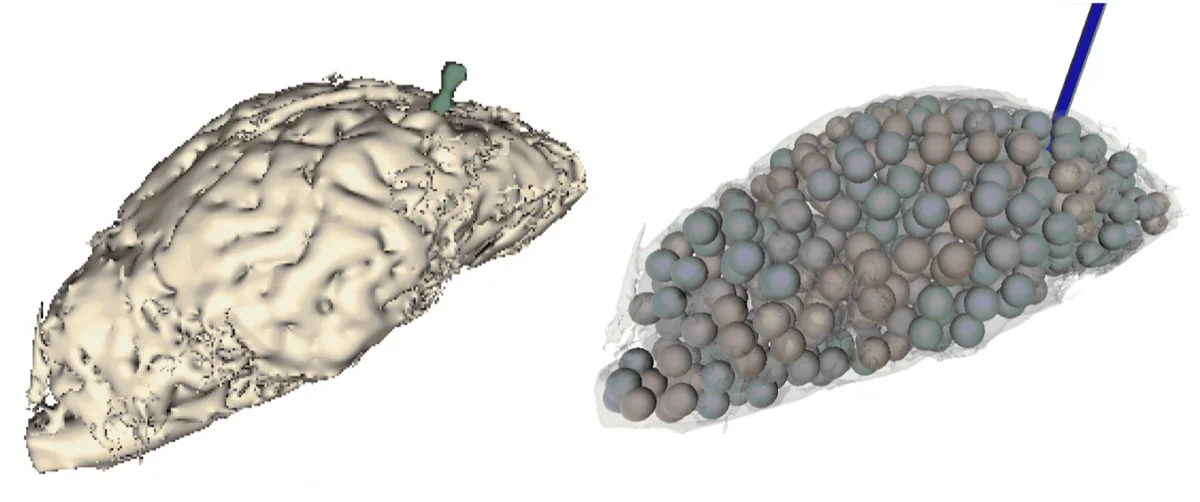
A position-based dynamics model of brain deformation for keyhole neurosurgery, and a VR and haptics trainer for Veress needle insertion.
Keypoint matching that sees beyond RGB with hyperspectral imaging, a robotic rig for multi-view laparoscopic capture, and a hard look at where image matching benchmarks break down.
Now AI Lead and Founding Applied Scientist at morph , since Oct 2024.
Three to start with, then all 13, which you can filter by stage of the perception pipeline, first author or journal.
Under reviewCited by 4: Measuring proximity to standard planes during fetal brain ultrasound scanning
AURIS/IPCAI Young Investigator Travel Award, 1st placeCited by 25: Deep learning-based plane pose regression in obstetric ultrasound
No papers match these filters.
* Equal contribution. Citation counts refresh weekly from Google Scholar.
Looking for a speaker, reviewer or committee member?
Chiara Di Vece builds real-time perception for things that move, from ultrasound probes to soft robots. Chiara is AI Lead at morph and holds a PhD in Computer Science from UCL.
Invited presenter Innovation in Women's Health Tech 2025, Impact Hub London
Invited presenter Women in Medical Image Understanding and Analysis (WiMIUA), University of Cambridge
Lecturer and organiser PhD Spring School, Università della Calabria
Invited speaker SharedCity: Innovation, Participation and Sustainability in Cities of the Future, Milan
Outstanding Reviewer Award, IPCAI 2024, top 7% of reviewers
Reviewer for IEEE Transactions on Medical Imaging, Medical Image Analysis, MICCAI, CVPR, ECCV, ICRA, IROS, IEEE Robotics and Automation Letters, IPCAI, IJCARS, IEEE Access, EMBC
Where the work began, and where it is now.
Leading AI development at a stealth-stage soft robotics startup, with a focus on computer vision, physical AI, robotics and AI agents.
AI SuitUpRemote (Albuquerque, US)
Research and prototyping for generative AI headshots. Optimised face detection, alignment and style transfer pipelines across diverse demographics, and cut inference time for web-scale deployment.
MathWorksCambridge, UK
Extended the Deep Learning Toolbox with a differentiable sort, fully supported by the automatic differentiation engine, so users can build custom layers that sort.
University College London
Sole researcher on the AI-guided fetal brain ultrasound line in the Surgical Robot Vision group and UCL Hawkes Institute, supervised by Danail Stoyanov and Francisco Vasconcelos. Took sensorless 6D plane pose estimation from first principles to a real-time navigation pipeline (3 ms latency) on NVIDIA's Clara AGX clinical platform, with NVIDIA's Holoscan team. TA for Reinforcement Learning (with Google DeepMind), Robotic Systems, Machine Learning and Mathematical Modelling.
Politecnico di Milano, NEARLabMilan, Italy
NeuroEngineering and Medical Robotics Lab, EU project EDEN2020. Built a real-time, position-based dynamics simulator of brain deformation for keyhole neurosurgery in Unity, validated against in-vivo animal data (mean mismatch 4.73 ± 2.15%). Published in IEEE RA-L and presented at IROS.
University of Illinois ChicagoChicago, US
Developed a haptics and VR simulator for Veress needle insertion training, rated "good" on the System Usability Scale by experienced clinicians. TA for Biological Systems Analysis.
15 competitive awards, plus 3 degree honours.
Thirteen high school and undergraduate mentees guided from research question to paper, five of them published or accepted, including at the International Conference on Human-Computer Interaction.
Advised eight MSc, visiting and summer students on ultrasound pose estimation, haptic ultrasound simulators, clinical video tracking and surgical teleoperation.